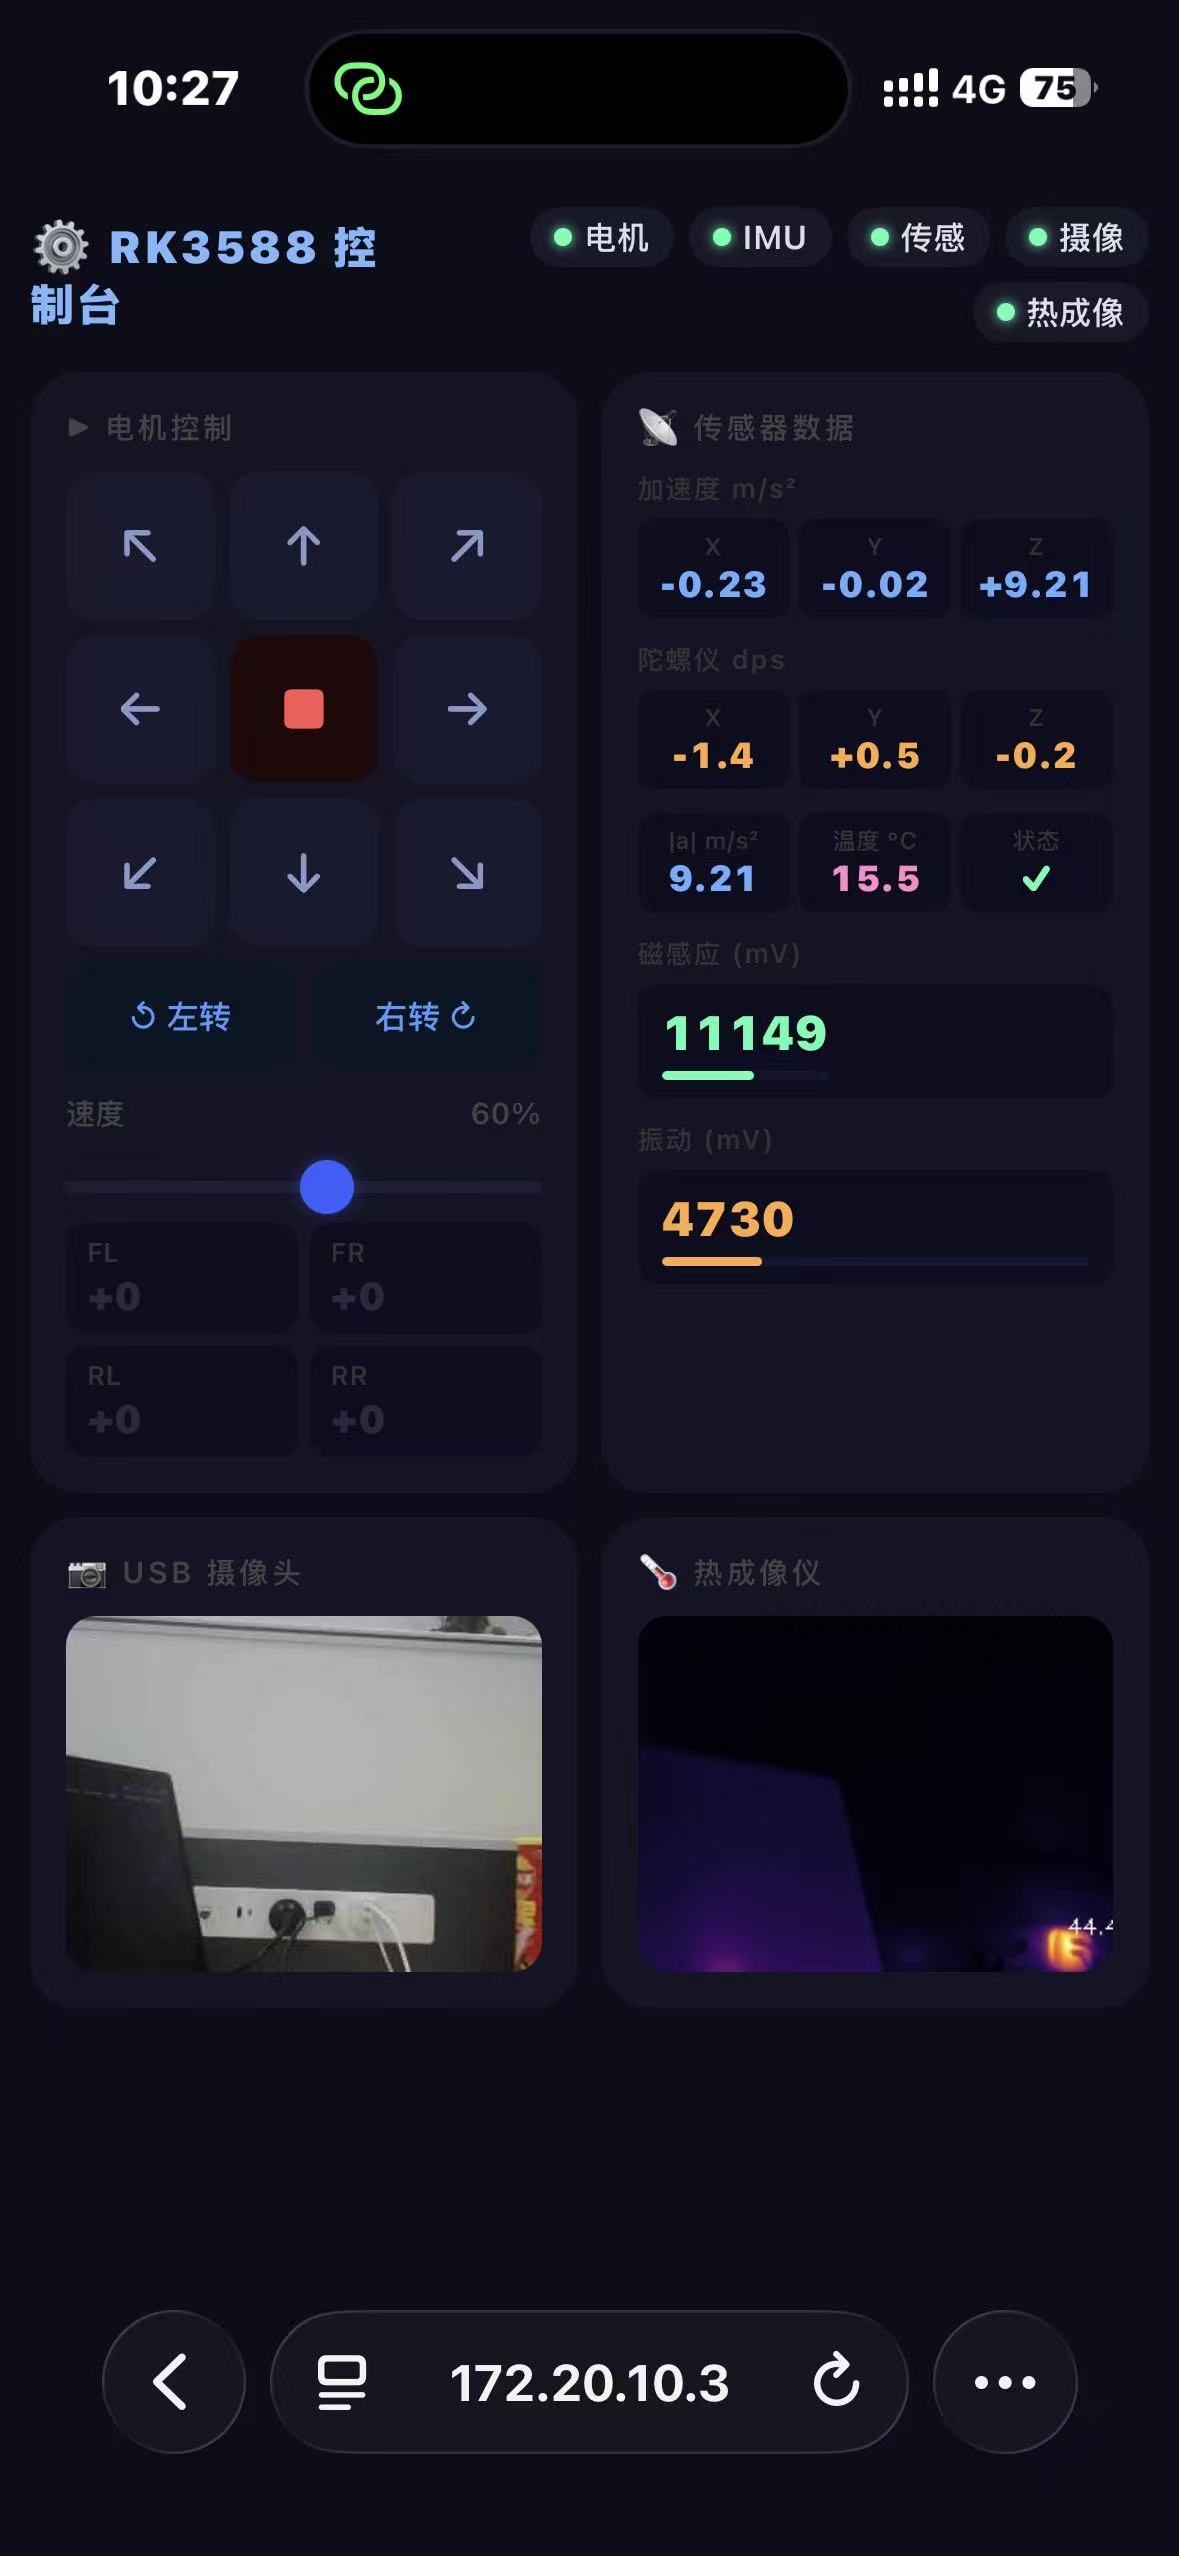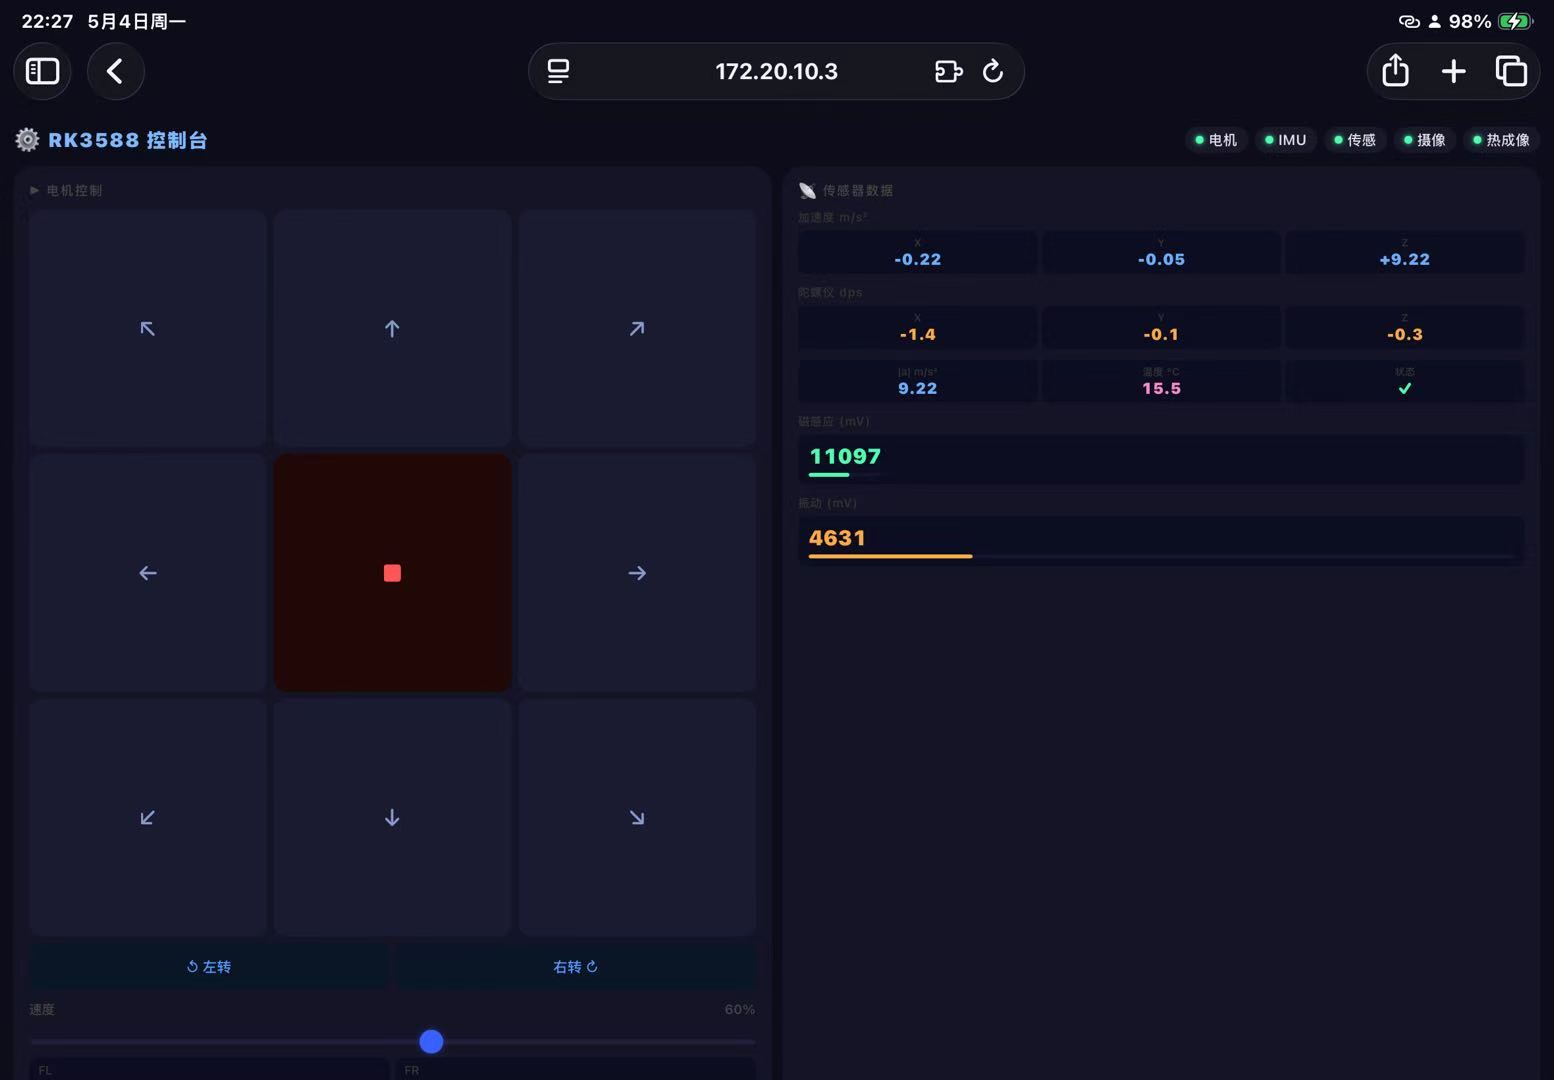
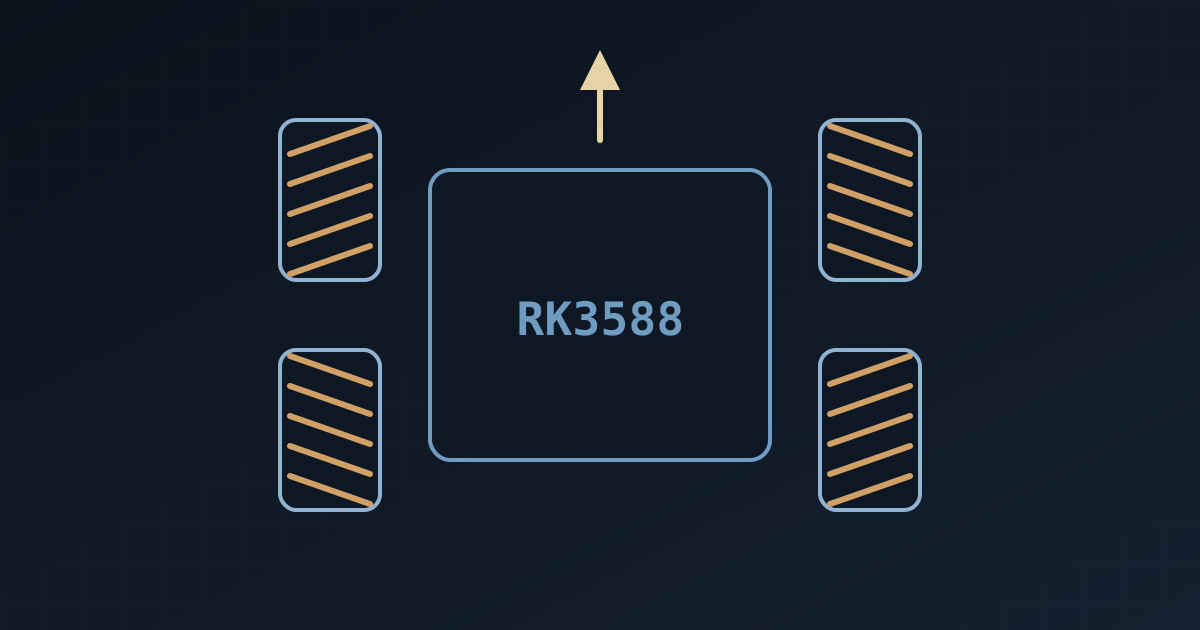
This project implements a four-wheel mecanum robot built on an RK3588 development board. Any device on the same WiFi network (phone, tablet or computer) can control the robot remotely through a web browser. The system integrates thermal-imaging temperature acquisition, six-axis IMU monitoring and real-time USB camera streaming, and the front-end page is adapted to mobile touch screens. The project is open-sourced on GitHub: Yu-Xiang-Yang/rk3588-multimodal-mecanum.